Capability / robustness testing
Test How Charging Systems Handle Unexpected Messages
Control the simulated EV or EVSE: vary communication parameters and test responses to communication errors. Alongside CCS PLC simulation, DC-China (GB/T DC) and CHAdeMO Professional Sim provide advanced CAN controls for repeatable robustness tests.
The decisive difference
Configure charging behaviour. Keep the sequence in view.
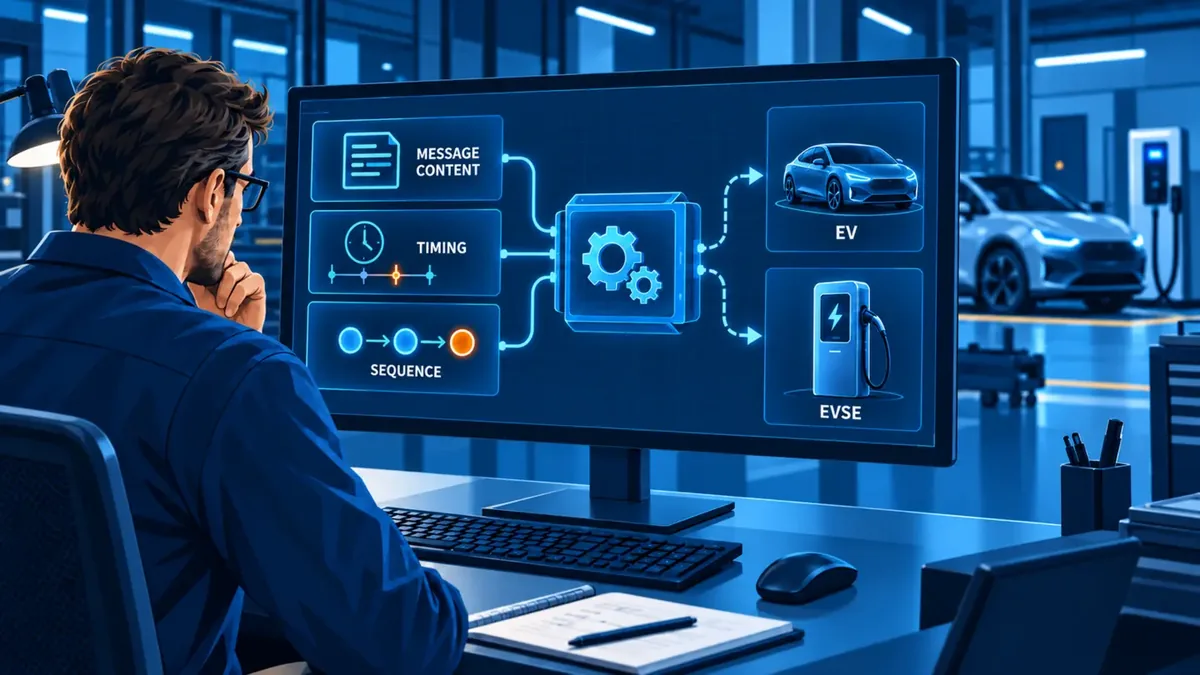
Professional Simulation controls a simulated charging partner; Manipulating Gateway keeps the real EV and EVSE connected. CCS Professional Sim provides PLC parameter, timing and additional-message controls. DC-China (GB/T DC) and CHAdeMO each provide Professional Sim in both EV and EVSE directions, with advanced parameters and communication-error simulation.
Explore the supported parameters in an application-focused interface and see how they affect the charging sequence. Customers also use this interaction to understand DIN 70121 and ISO 15118-2/-3 charging processes while developing their own implementation.
Four control domains
Move beyond “valid or invalid” and control the actual failure mechanism.
Set protocol-specific parameters
For CCS PLC, use valid or invalid DIN 70121 and ISO 15118-2 message parameters within the XML schema ranges. For DC-China (GB/T DC) and CHAdeMO, configure advanced parameters in both EV and EVSE Professional Sim.
Control message availability
For DC-China and CHAdeMO, configure CAN message loss (CAN loss), including its frequency, to test the DUT response to missing communication. CCS supports suppression or omission of supported optional behaviour.
Change timing by message
For DC-China and CHAdeMO, set CAN cycle times per message type. For CCS, vary individual-message timing and test responses to defined delays and timeout conditions.
Challenge the state machine
Test state-machine robustness in CCS, DC-China and CHAdeMO. Use protocol-specific error controls and observe transitions and recovery. CCS additionally supports injecting messages into the charging sequence.
CAN communication
DC-China and CHAdeMO: Professional Sim for EV and EVSE
Both charging standards offer Professional Sim in both directions. Configure advanced parameters, simulate communication errors and test the robustness of the state machine. Set CAN message loss (CAN loss) and its frequency, and adjust CAN cycle times separately for each message type.
A disciplined robustness workflow
Change one condition. Correlate the whole response.
Professional Simulation is most valuable when the deviation is intentional, attributable and reusable.
Define the baseline
Select the EV or EVSE test role, charging standard and expected normal response.
Configure the challenge
Set message values, timing or additional message injection to test one defined behaviour.
Observe the DUT
Run the scenario and correlate state transitions with communication, pilot signals, voltage and current.
Repeat and compare
Save the configuration, compare it with the baseline and reuse it to check software changes.
Example: a delayed response
Change the timing. Understand the reaction.
- Record the baselineRun the configured EV simulation against the EVSE and retain the normal response.
- Change one supported message timingSelect the message and vary its response delay within the available controls. The selected protocol and release define the options.
- Evaluate the DUT reactionUse the configured analysis to inspect the timing deviation, subsequent states and measured response. Decide what to investigate next.
- Save and repeatReuse the simulation configuration after a software change and compare the result with the baseline.
Where it changes the decision
One capability, three distinct engineering moments.
Controller robustness
Explore validation, recovery and safe-state behaviour while the implementation can still be changed quickly.
Hard-to-reach boundary cases
Reproduce timing and sequence conditions that are unreliable, unsafe or expensive to create with real charging partners.
Repeatable regression
Store an approved behaviour configuration and rerun it after software, parameter or hardware changes.
Configuration boundary
Specify the question before selecting the licence and hardware path.
Define the DUT role, charging standard and edition, normal partner, message or state to vary, required physical signals, electrical depth, automation target and evidence output.
Questions before configuration
Professional Simulation, precisely scoped.
Is this the same as a Conformance Test Library?
Does every test require programming?
Can it test both EV and EVSE implementations?
Can configured behaviour be automated?
What should be supplied for configuration?
Controlled partner behaviour
Define the behaviour you need to challenge.
Specify the simulated role, standard, value, timing or sequence variation and measured response.